Multi-perspective capture, built for manipulation learning
Egocentric video is our core product. Alongside it we capture complementary views and sensor streams, so a single task can be studied from several angles.
Core product
Egocentric (first-person)
4K / 60 FPS · EgoCAM wearable cap and chest-mount rigs
Natural hand-eye perspective with non-rigid contact dynamics: fabric, dough, cables, liquids and tools, exactly as skilled workers handle them.
Stereo camera + IMU
Depth-capable stereo capture (monocular and binocular) with motion-sensor streams for spatial and 3D reasoning.
Head-mounted video + IMU
Head-mounted capture synchronised with inertial data for ego-motion context, across household and daily-living tasks.
Dashcam / vehicle
Road and in-vehicle perspectives for mobility and logistics work.
Also available
- Indic multilingual speech & audio
- Call-center audio samples
Robots learn dexterity by watching hands, not reading text
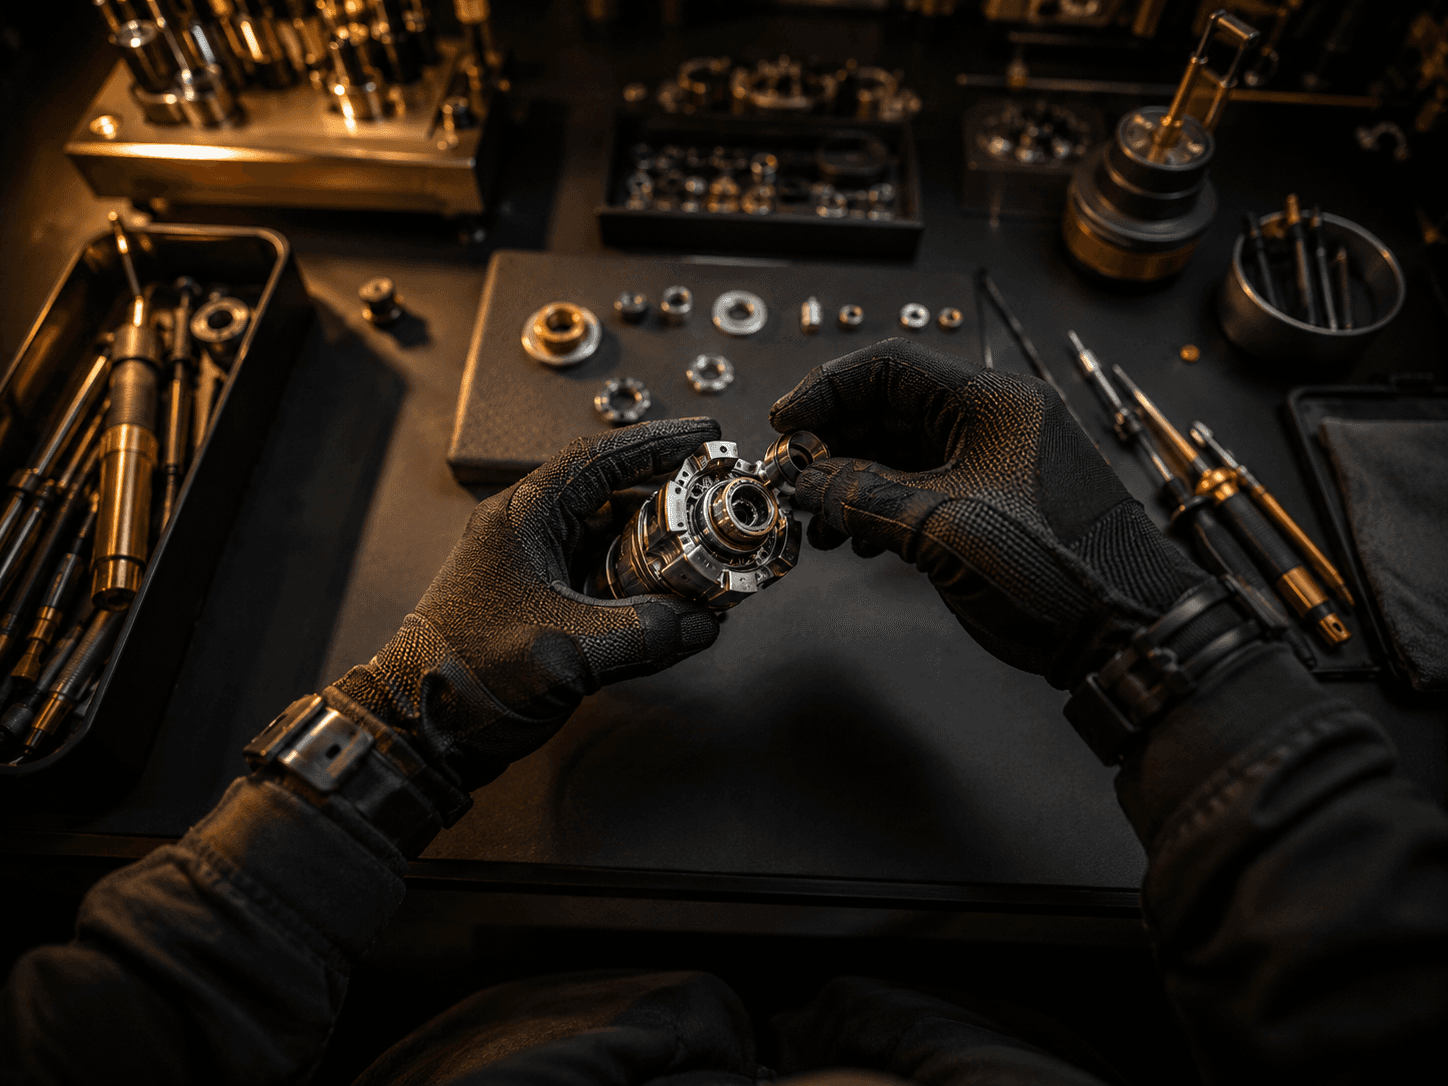
Egocentric footage is shot from the worker's own point of view: what their eyes and hands see as they work. A camera at head or chest level records every grip, twist, fold, weld and stitch the way the worker performs it.
Dexterous policies need many real demonstrations of real tasks, seen from the viewpoint the robot will one day have. That data is slow and expensive to collect, which is why we built the collection network ourselves.
- Real workplaces, not staged labs
- Skilled operators performing tasks at working speed
- Natural variation in tools, materials and environments
Ready to see samples?
Tell us the tasks, environments and hours you need and we will send matching samples.